About Me
I am a Ph.D. candidate in Computer Science at the University at Buffalo, working in the Distributed Robotics and Networked Embedded Sensing (DRONES) Lab Prof. Karthik Dantu. From January to July 2026, I was a Research Scientist Intern at Mitsubishi Electric Research Laboratories (MERL), Cambridge, where I worked with Dr. Stefano Di Cairano.
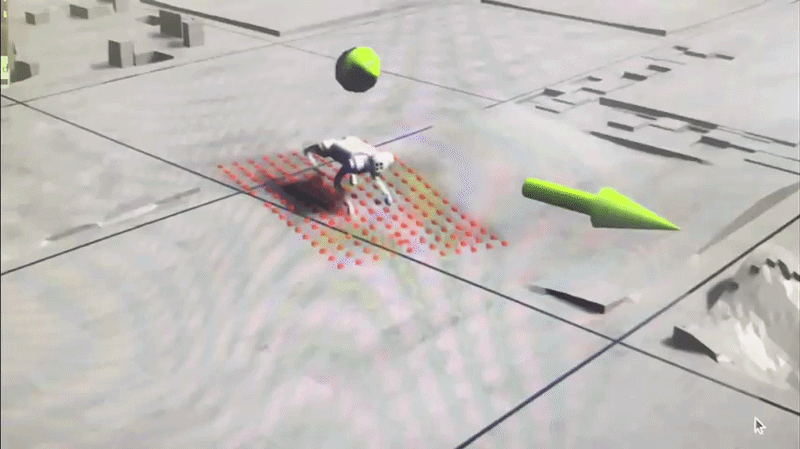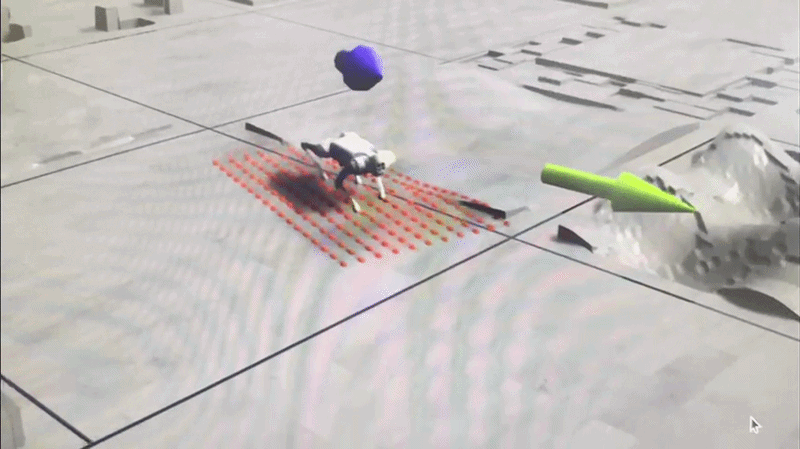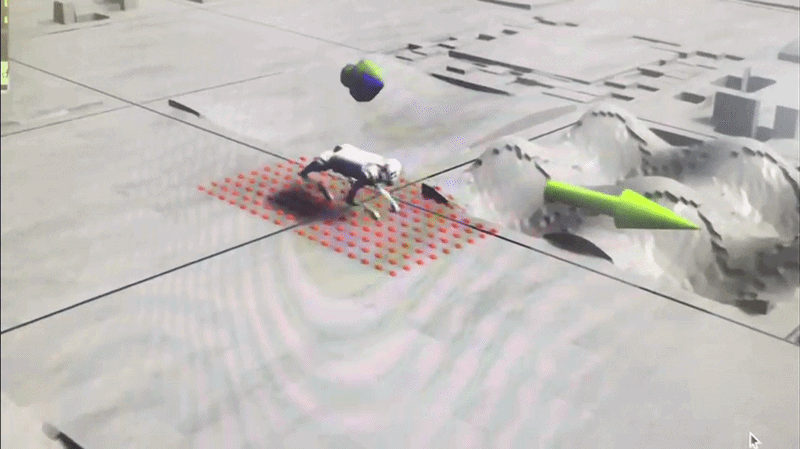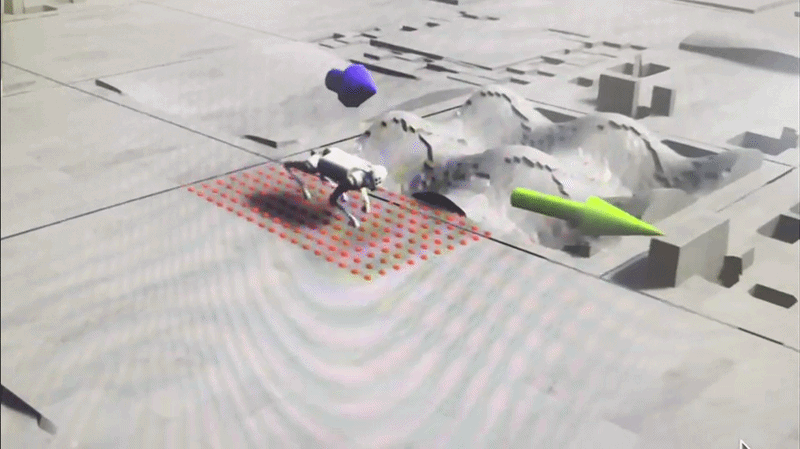
My research focuses on enabling legged robots to navigate complex and unseen terrains using uncertainty-aware perception and planning. I develop learning-based methods for predicting future footholds, modeling epistemic uncertainty, and generating feasibility-aware costmaps for robust navigation.
More broadly, I am interested in bridging perception, control, and planning to build autonomous robotic systems that can reliably operate in real-world environments — with an emphasis on generalization and safety in out-of-distribution scenarios.
News
Nov 2026
Invited to speak at the NXT AI conference in Boston — sharing my research on reliable legged autonomy.
Oct 2026
Successfully defended my Ph.D. thesis proposal — “Learning from Physical Interaction for Reliable Legged Autonomy,” on October 30, 2026.
2026
CART accepted at ISRR 2026 — our work on context-aware terrain adaptation for stable legged locomotion will be presented in Malaysia.
2026
Paper accepted at CLAWAR 2026 — Task-Conditioned Uncertainty Costmaps for Legged Locomotion.
Jan 2026
Joined MERL as Research Scientist Intern — working on uncertainty-aware perception and planning for legged robots at Mitsubishi Electric Research Laboratories, Cambridge.
May 2025
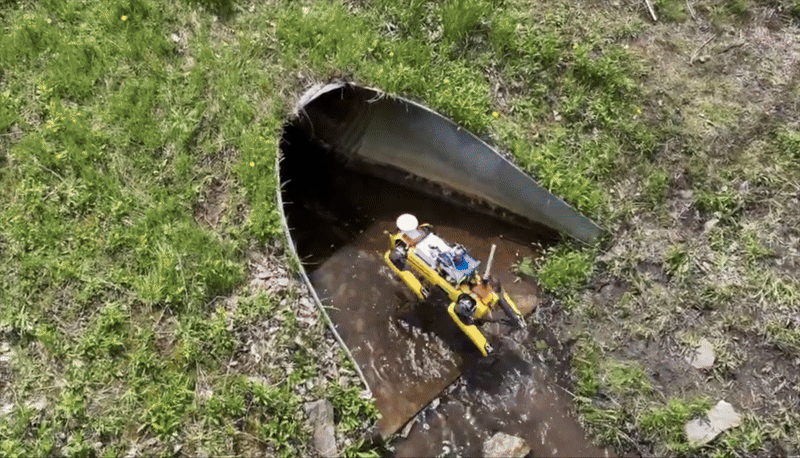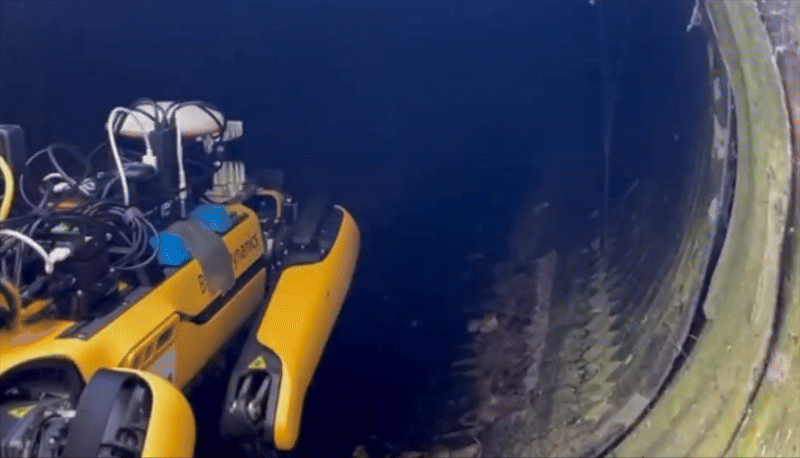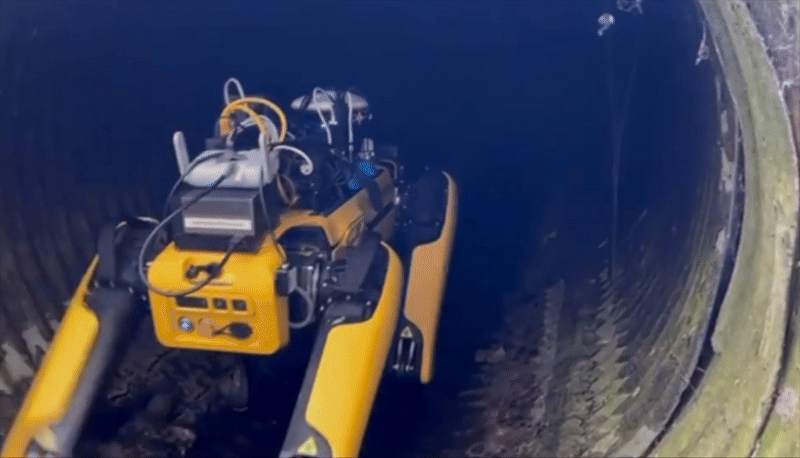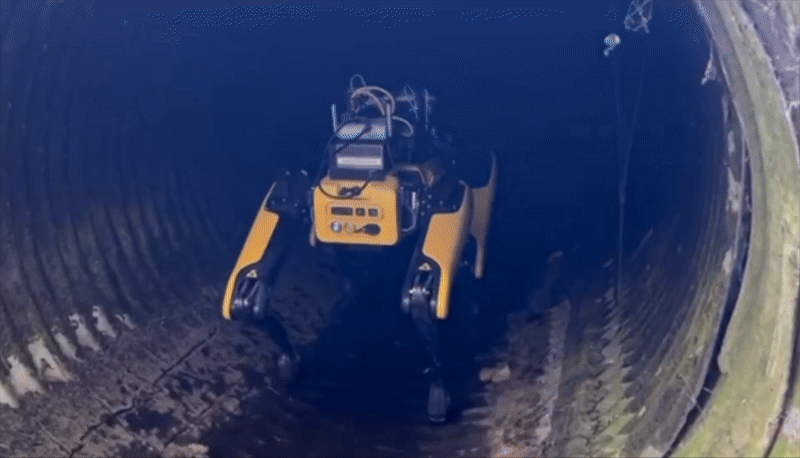
Recognized among the top 10 emerging researchers at ICRA 2025's Workshop on Field Robotics — presented our work on autonomous culvert inspection using legged robots in Atlanta, Georgia.
May 2024
Represented SUNY Buffalo at AI Expo, Albany NY — connected with SUNY Chancellor Dr. John B. King and state policymakers.